
AP Physics C Mechanics - 6.1 Rotational Kinetic Energy- Exam Style questions- FRQs
Rotational Kinetic Energy AP Physics C Mechanics FRQ
Unit 6: Energy and Momentum of Rotating Systems
Weightage : 10-15%
Question
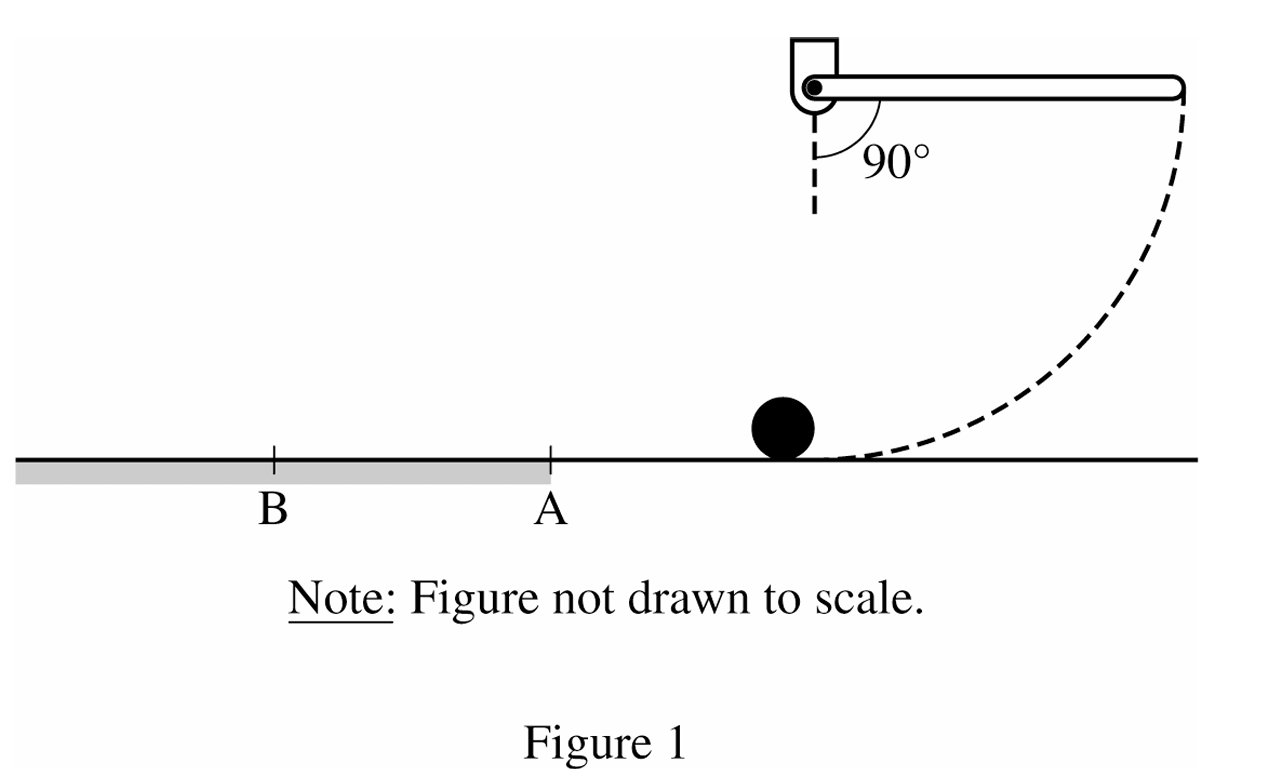
Most-appropriate topic codes (AP Physics C: Mechanics):
• Topic \(6.4\) — Conservation of Angular Momentum (Part \( \mathrm{b} \))
• Topic \(2.2\) — Forces and Free-Body Diagrams (Part \( \mathrm{c} \))
• Topic \(5.6\) — Newton’s Second Law in Rotational Form (Part \( \mathrm{d} \))
• Topic \(6.5\) — Rolling (Part \( \mathrm{e} \))
▶️ Answer/Explanation
We solve this sequence by first applying conservation of mechanical energy as the rod swings downward, converting potential energy into rotational kinetic energy. During the perfectly inelastic collision with the sphere, the net external torque is zero, so the system’s angular momentum is conserved. Once the sphere begins sliding across the rough surface, kinetic friction acts against its motion, resulting in a constant linear deceleration. Simultaneously, this frictional force produces a torque that creates an angular acceleration, causing the sphere’s rotation to increase. These dual kinematic changes persist until the sphere’s linear and rotational velocities perfectly synchronize into rolling without slipping.
(a)
\(\Delta U + \Delta K = 0\)
\((0 – Mgh_{CM}) + \left(\frac{1}{2}I\omega_f^2 – 0\right) = 0\)
Substitute \(M = 2m\), \(h_{CM} = \frac{\ell}{2}\), and \(I = \frac{1}{3}(2m)\ell^2\):
\((2m)g\left(\frac{\ell}{2}\right) = \frac{1}{2}\left(\frac{2}{3}m\ell^2\right)\omega_f^2\)
\(mg\ell = \frac{1}{3}m\ell^2 \omega_f^2\)
\(\boxed{\omega_f = \sqrt{\frac{3g}{\ell}}}\)
(b)
\(L_i = L_f\)
\(I_{rod}\omega_f = m v_0 \ell\)
\(\left(\frac{2}{3}m\ell^2\right)\sqrt{\frac{3g}{\ell}} = m v_0 \ell\)
\(v_0 = \frac{2}{3}\ell\sqrt{\frac{3g}{\ell}}\)
\(\boxed{v_0 = \sqrt{\frac{4}{3}g\ell}}\)
(c)
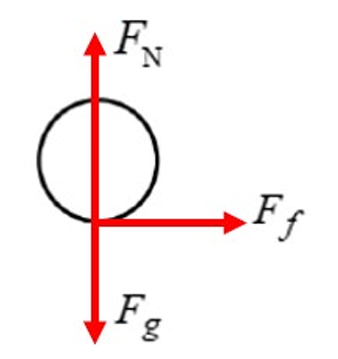
• The normal force \(F_N\) points directly upward from the bottom of the sphere.
• The force due to gravity \(F_g\) points directly downward from the center of mass.
• The frictional force \(F_f\) points horizontally to the right from the bottom of the sphere.
(d)(i)
\(\Sigma F = ma\)
\(-\mu m g = m a\)
\(a = -\mu g\)
\(v = v_0 + at\)
\(\boxed{v = v_0 – \mu g t}\)
(d)(ii)
\(\tau_{net} = I\alpha\)
\(F_f R = \frac{2}{5}mR^2 \alpha\)
\(\mu m g R = \frac{2}{5}mR^2 \alpha\)
\(\alpha = \frac{5\mu g}{2R}\)
\(\omega = \omega_0 + \alpha t\)
\(\boxed{\omega = \frac{5\mu g}{2R} t}\)
(e)(i)
Rolling without sliding occurs when \(v = R\omega\).
\(v_0 – \mu g t = R\left(\frac{5\mu g}{2R}t\right)\)
\(v_0 – \mu g t = \frac{5}{2}\mu g t\)
\(v_0 = \frac{7}{2}\mu g t\)
\(\boxed{t = \frac{2v_0}{7\mu g}}\)
(e)(ii)
Substitute \(t\) into the linear velocity equation:
\(v = v_0 – \mu g\left(\frac{2v_0}{7\mu g}\right)\)
\(v = v_0 – \frac{2}{7}v_0\)
\(\boxed{v = \frac{5}{7}v_0}\)