
AP Physics C Mechanics - 2.1 Systems and Center of Mass- Exam Style questions- FRQs
Systems and Center of Mass AP Physics C Mechanics FRQ
Unit 2: Force and Translational Dynamics
Weightage : 20-15%
Question
Most-appropriate topic codes (AP Physics C: Mechanics):
• Topic \(5.3\) — Torque (Parts \(\mathrm{d}, \mathrm{e}\))
• Topic \(5.4\) — Rotational Inertia (Parts \(\mathrm{a}, \mathrm{c}\))
• Topic \(6.1\) — Rotational Kinetic Energy (Part \(\mathrm{f}\))
▶️ Answer/Explanation
(a)
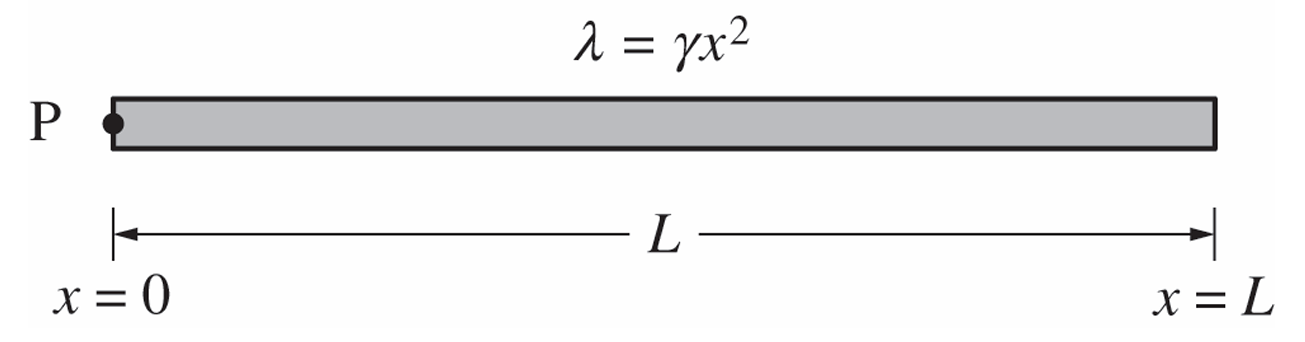
To find the rotational inertia using integral calculus, we start with the fundamental definition of rotational inertia, \(I = \int r^2 dm\). We can substitute the mass element \(dm = \lambda dx\) and the given linear mass density \(\lambda = \gamma x^2\) to write the entire integral in terms of \(x\). Finally, evaluating the integral from \(x=0\) to \(x=L\) gives us the intended expression.
\( I = \int_0^L x^2 (\gamma x^2) dx \)
\( I = \int_0^L \gamma x^4 dx \)
\( I = \gamma \left[ \frac{x^5}{5} \right]_0^L \)
\( I = \left(\frac{3M}{L^3}\right) \left(\frac{L^5}{5} – 0\right) \)
\( \boxed{I = \frac{3}{5}ML^2} \)
(b)
The horizontal location of the center of mass can be found using the continuous center of mass formula, \(X_{CM} = \frac{\int x dm}{\int dm}\). Since we know the total mass is \(M\), we can substitute \(dm = \lambda dx\) and evaluate the integral in the numerator from \(x=0\) to \(x=L\) independently.
\( X_{CM} = \frac{\int_0^L x (\gamma x^2) dx}{M} \)
\( X_{CM} = \frac{\int_0^L \gamma x^3 dx}{M} \)
\( X_{CM} = \frac{\gamma \left[ \frac{x^4}{4} \right]_0^L}{M} \)
\( X_{CM} = \frac{\left(\frac{3M}{L^3}\right) \left(\frac{L^4}{4}\right)}{M} \)
\( \boxed{X_{CM} = \frac{3}{4}L} \)
(c)
Correct answer:
\( \boxed{\text{Greater than}} \)
Because more of the mass of the rod is at the end of the rod opposite point \(P\), a greater concentration of mass is located further away from the axis of rotation. Thus, the rotational inertia of the rod is greater around point \(P\) than around its own center of mass. Alternatively, according to the parallel axis theorem (\(I = I_{cm} + md^2\)), if the axis is positioned away from the center of mass, the rotational inertia will inherently be larger than if it were perfectly centered.
(d)
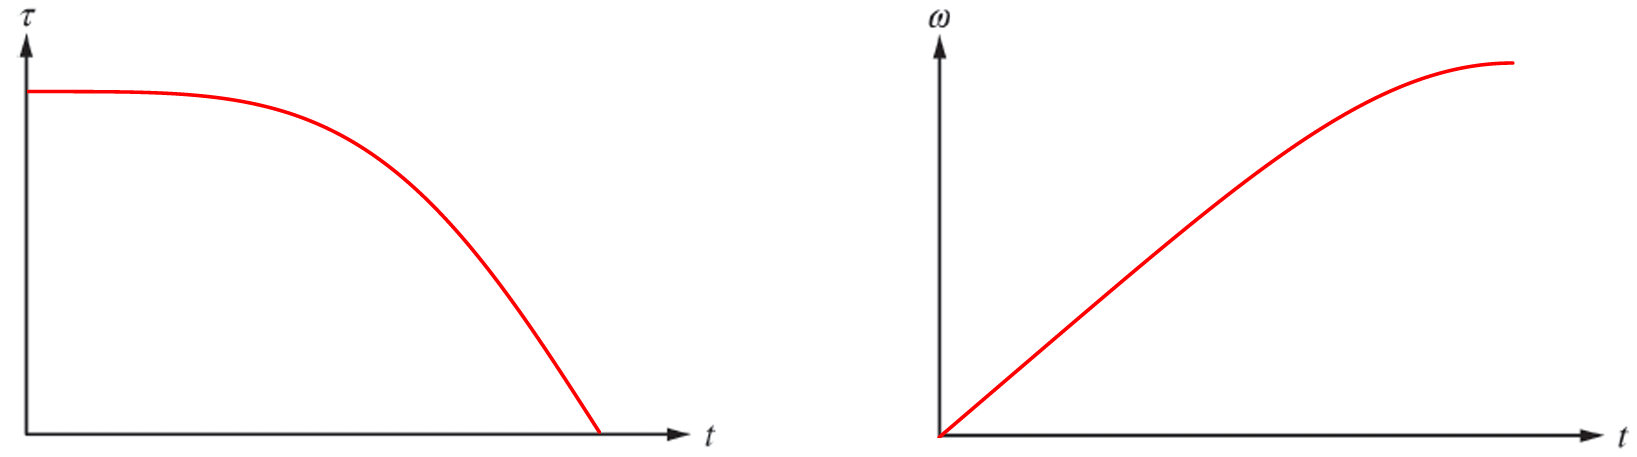
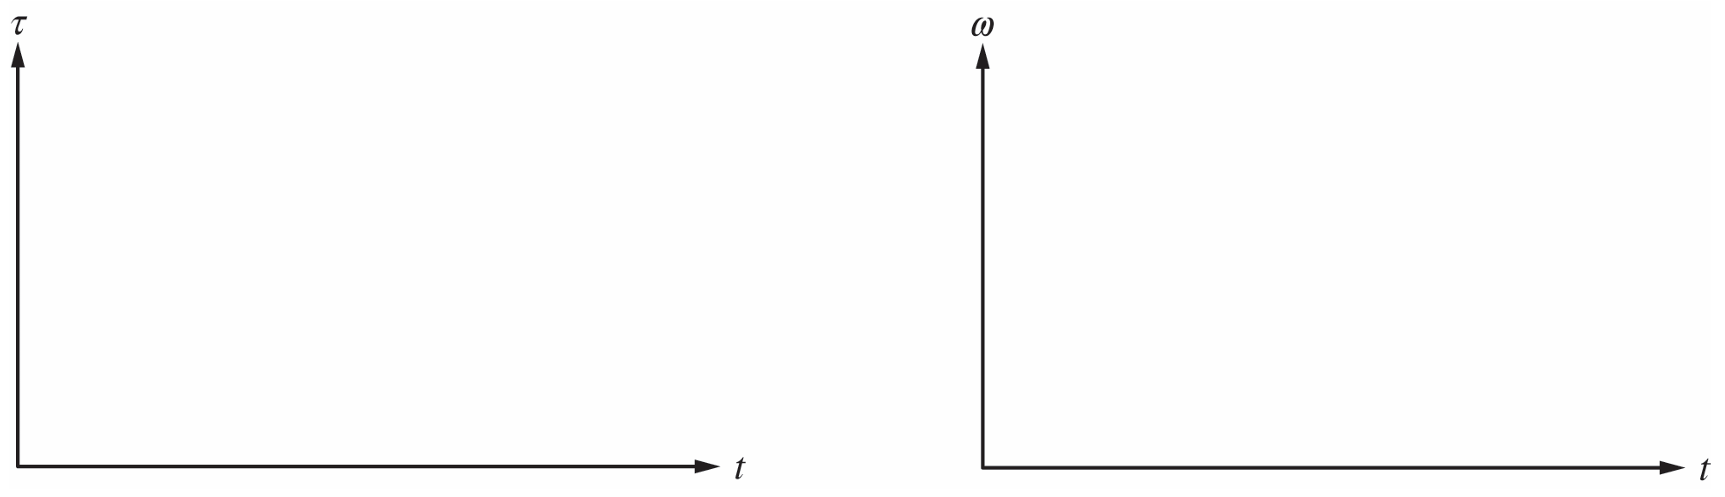
For the torque graph, we sketch a concave down curve that smoothly decreases to zero as the rod swings to the lowest vertical point. For the angular speed graph, we sketch a concave down curve that begins at zero and approaches a horizontal asymptote as time increases. The slope of the angular speed graph represents angular acceleration, which is proportional to the decreasing torque, ensuring consistency and a physical linkage between the two graphs.
(e)
Correct answer:
\( \boxed{\text{Decreasing}} \)
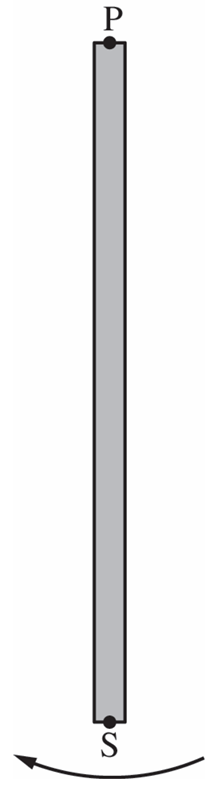
As the rod rotates downward, the angle in the torque equation \(\tau = rF\sin\theta\) naturally decreases. Consequently, the perpendicular lever arm between point \(P\) and the rod’s center of mass continues to shrink; thus, the torque on the rod decreases over time, meaning the magnitude of the angular acceleration must also decrease.
(f)
We can use the principle of conservation of mechanical energy to calculate the speed of the rotating rod exactly at its lowest point. By setting the initial gravitational potential energy equal to the final rotational kinetic energy, we find the final angular speed \(\omega_f\), and then use the relation \(v = \omega_f L\) to calculate the linear speed of point \(S\).
\( U_{i} + K_{i} = U_{f} + K_{f} \)
\( U_{i} = K_{f} \)
\( M g h_{i} = \frac{1}{2} I \omega_f^2 \)
\( M g \left(\frac{3}{4}L\right) = \frac{1}{2} \left(\frac{3}{5}ML^2\right) \left(\frac{v}{L}\right)^2 \)
\( \frac{3}{4} M g L = \frac{3}{10} M v^2 \)
\( v = \sqrt{\frac{5}{2} g L} \)
\( v = \sqrt{\frac{5}{2} (9.8\,\text{m/s}^2) (1.0\,\text{m})} \)
\( \boxed{v = 4.9\,\text{m/s}} \)