
AP Physics C Mechanics - 5.3 Torque- Exam Style questions- FRQs
Torque AP Physics C Mechanics FRQ
Unit 5: Torque and Rotational Dynamics
Weightage : 10-15%
Question
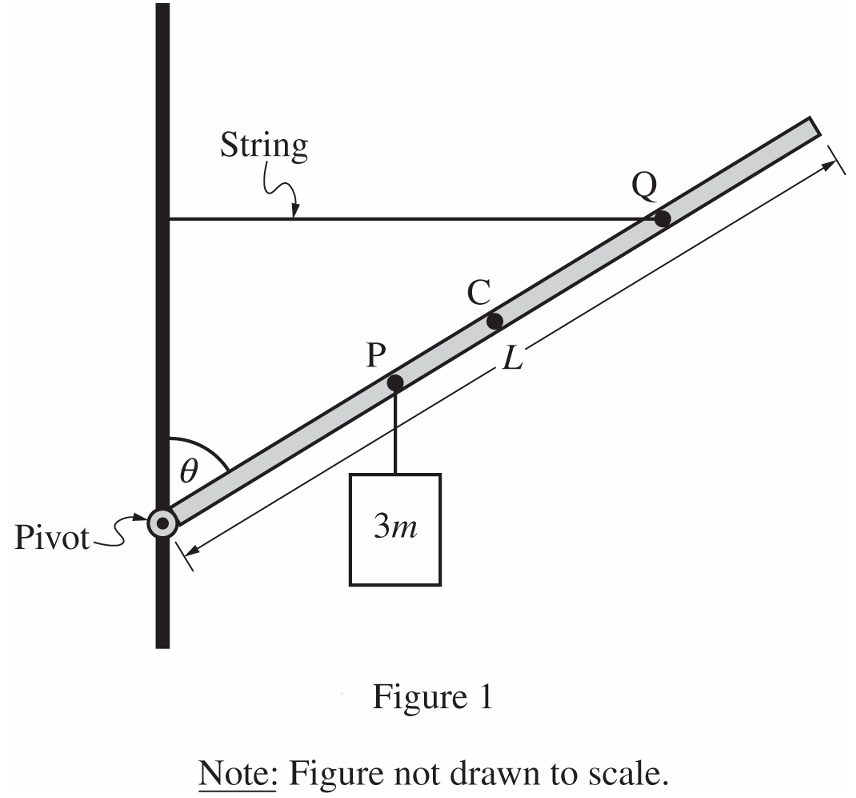
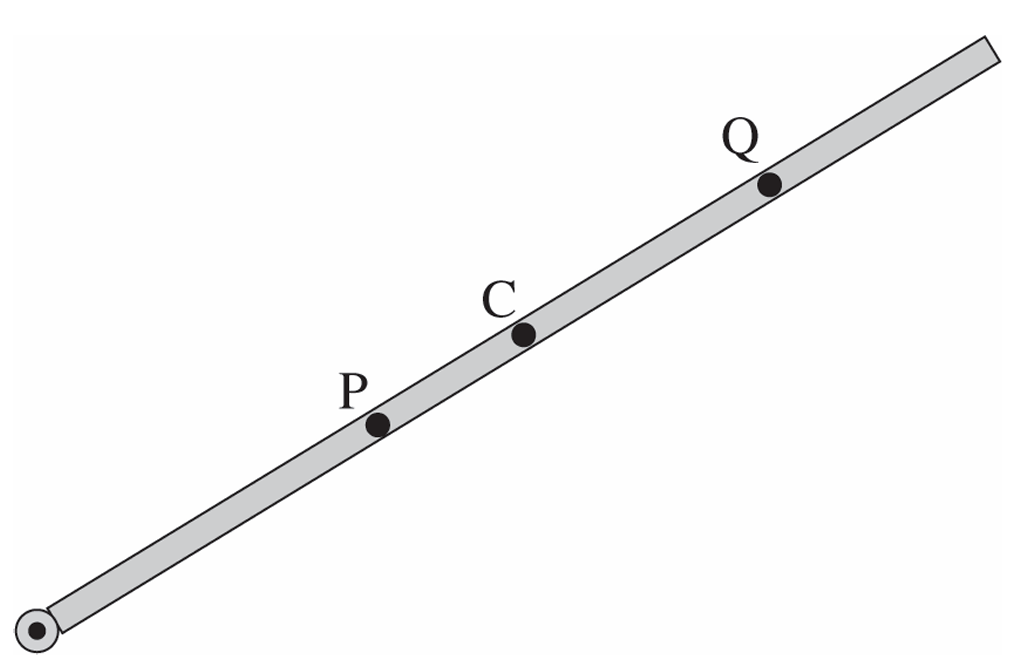
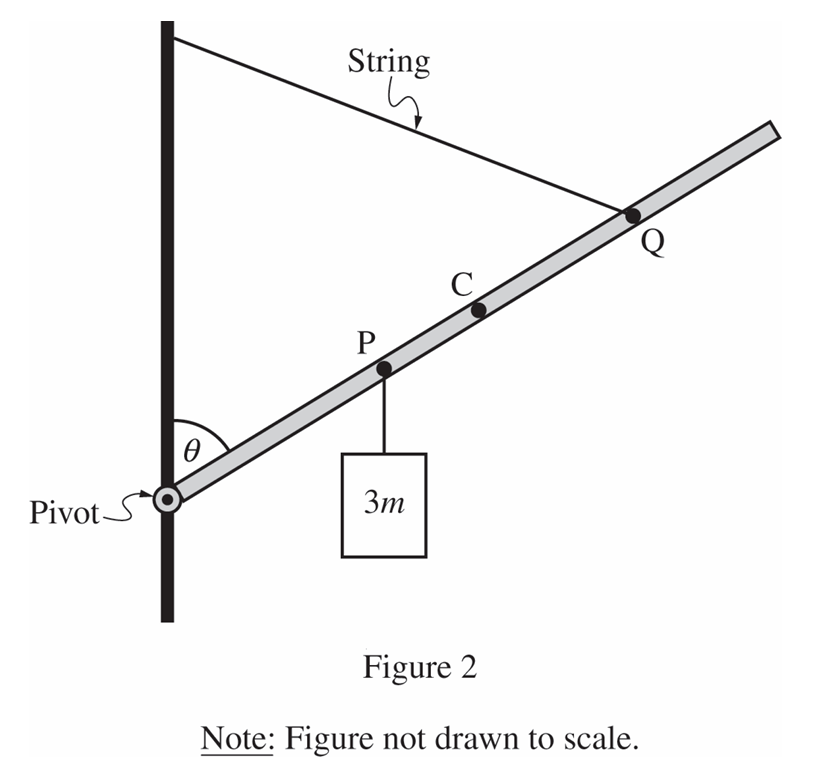
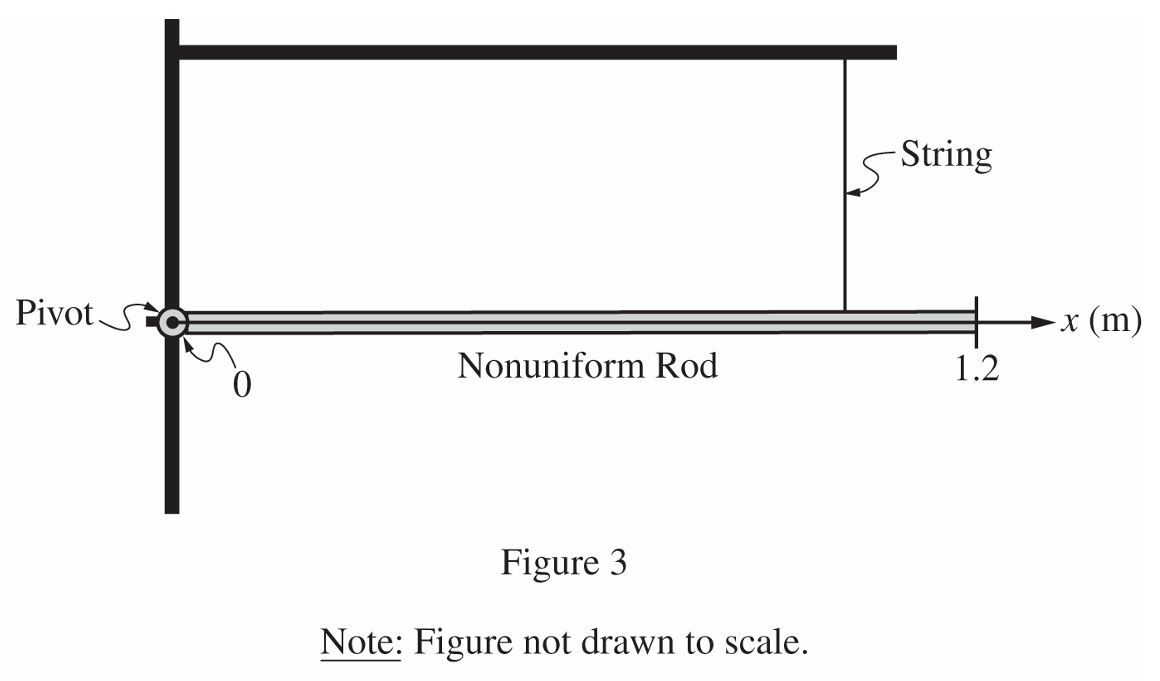
ii. Calculate the rotational inertia of the rod about the pivot.
Most-appropriate topic codes (AP Physics C: Mechanics):
• Topic 5.4 — Rotational Inertia (Part d)
• Topic 5.5 — Rotational Equilibrium and Newton’s First Law in Rotational Form (Parts a, b, c)
▶️ Answer/Explanation
(a)
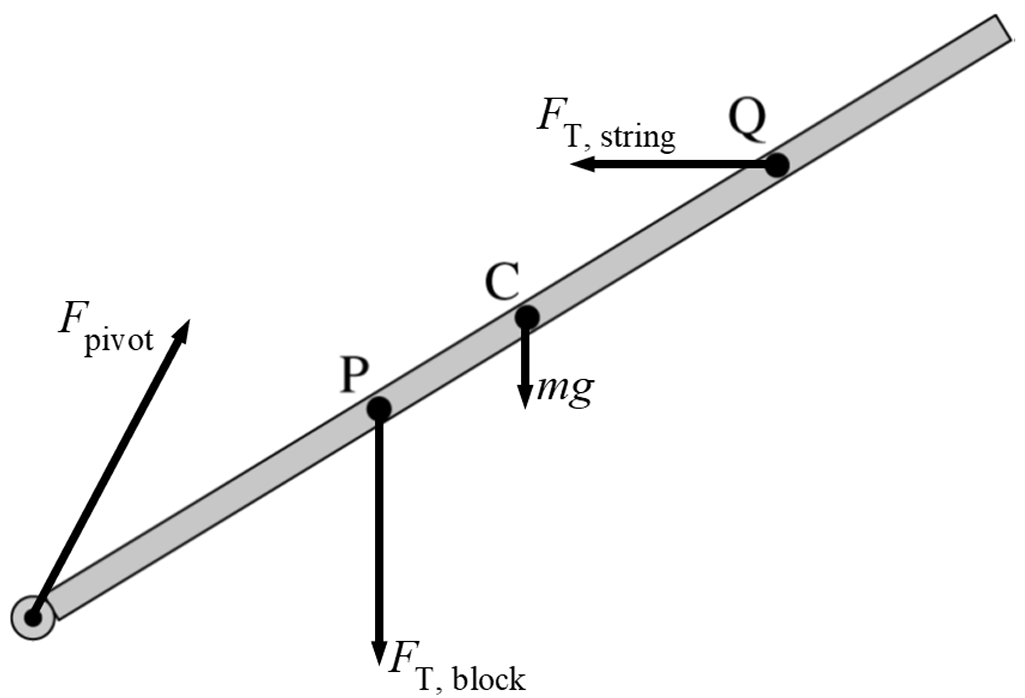
The free-body diagram should include four distinct forces originating from their respective points of application. We represent the weight of the rod pulling straight down from the center of mass, and the hanging block pulling straight down at P. The string pulls horizontally to the left at Q, and the pivot exerts a reaction force that generally points upward and to the right to support the system.
1. A downward arrow at Point C labeled $mg$ (force of gravity on the rod).
2. A downward arrow at Point P labeled $3mg$ (tension from the hanging block).
3. A horizontal arrow pointing left at Point Q labeled $F_T$ (tension from the string).
4. An arrow at the pivot pointing upward and rightward labeled $F_{\text{pivot}}$ (reaction force from the hinge).
(b)
To find the tension, we can use the condition for rotational equilibrium, meaning the net torque about the pivot is zero. We sum the clockwise torques from the weights of the rod and the hanging block, and set them equal to the counterclockwise torque from the horizontal string’s tension. By substituting the given distances and lever arms based on angle $\theta$, we solve the equation to isolate the tension force.
(c)
\( \boxed{F_{T,new} < F_T} \)
The new tension $F_{T,new}$ will be less than the original tension $F_{T}$. Because the mass and position of the rod and block remain unchanged, the total clockwise torque due to gravity stays the exact same. However, the new string’s line of action is angled higher, increasing its perpendicular distance (lever arm) from the pivot. Since the required counterclockwise torque remains constant and the lever arm has increased, a correspondingly smaller tension force is needed to maintain equilibrium.
(d)(i)
We find the total mass of the rod by integrating the given linear mass density function over its entire length from $x = 0$ to $x = 1.2\text{ m}$. Setting up the integral \(M = \int \lambda(x)\,dx\) and plugging in the given constants for $A$ and $B$, we perform a standard power rule integration. Evaluating this result at the $1.2\text{ m}$ boundary gives the total physical mass of the nonuniform rod.
(d)(ii)
To determine the rotational inertia of the nonuniform rod about the pivot, we integrate the second moment of mass, using the definition \(I = \int x^2\,dm\), which expands to \(I = \int x^2 \lambda(x)\,dx\). Distributing the $x^2$ into the density function and integrating term by term gives us the polynomial expression for inertia. Finally, plugging in the length bounds yields the final rotational inertia value.